
Module
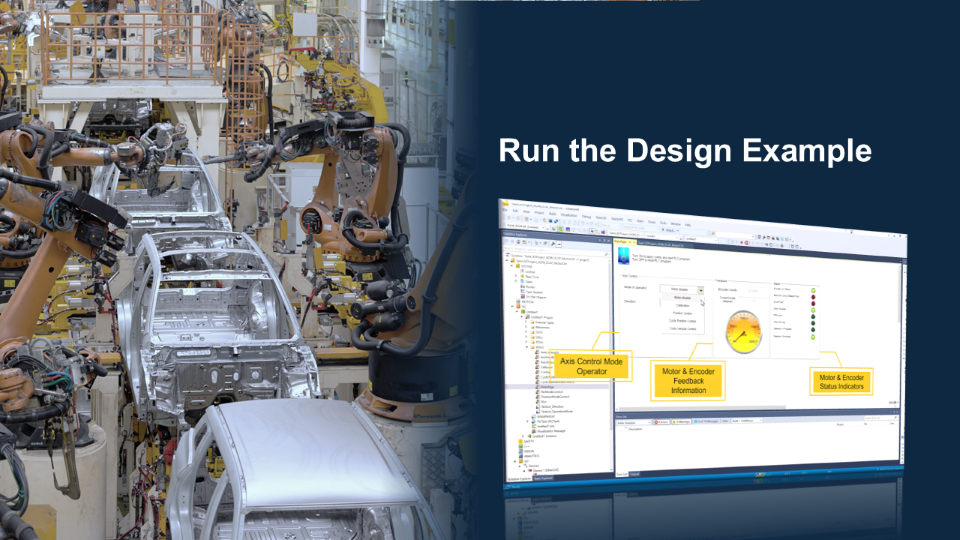
Run the Design Example
Intermediate.
09mins
Module Description
Set up and operate the TwinCAT-based motor control system by configuring the real-time core and cycle time. Then configure and verify each motor control mode—Calibration, Position, Cyclic Position, and Cyclic Velocity.
